AES / R-001
Robotics dossier
RNV1 Robotics
Active exploration
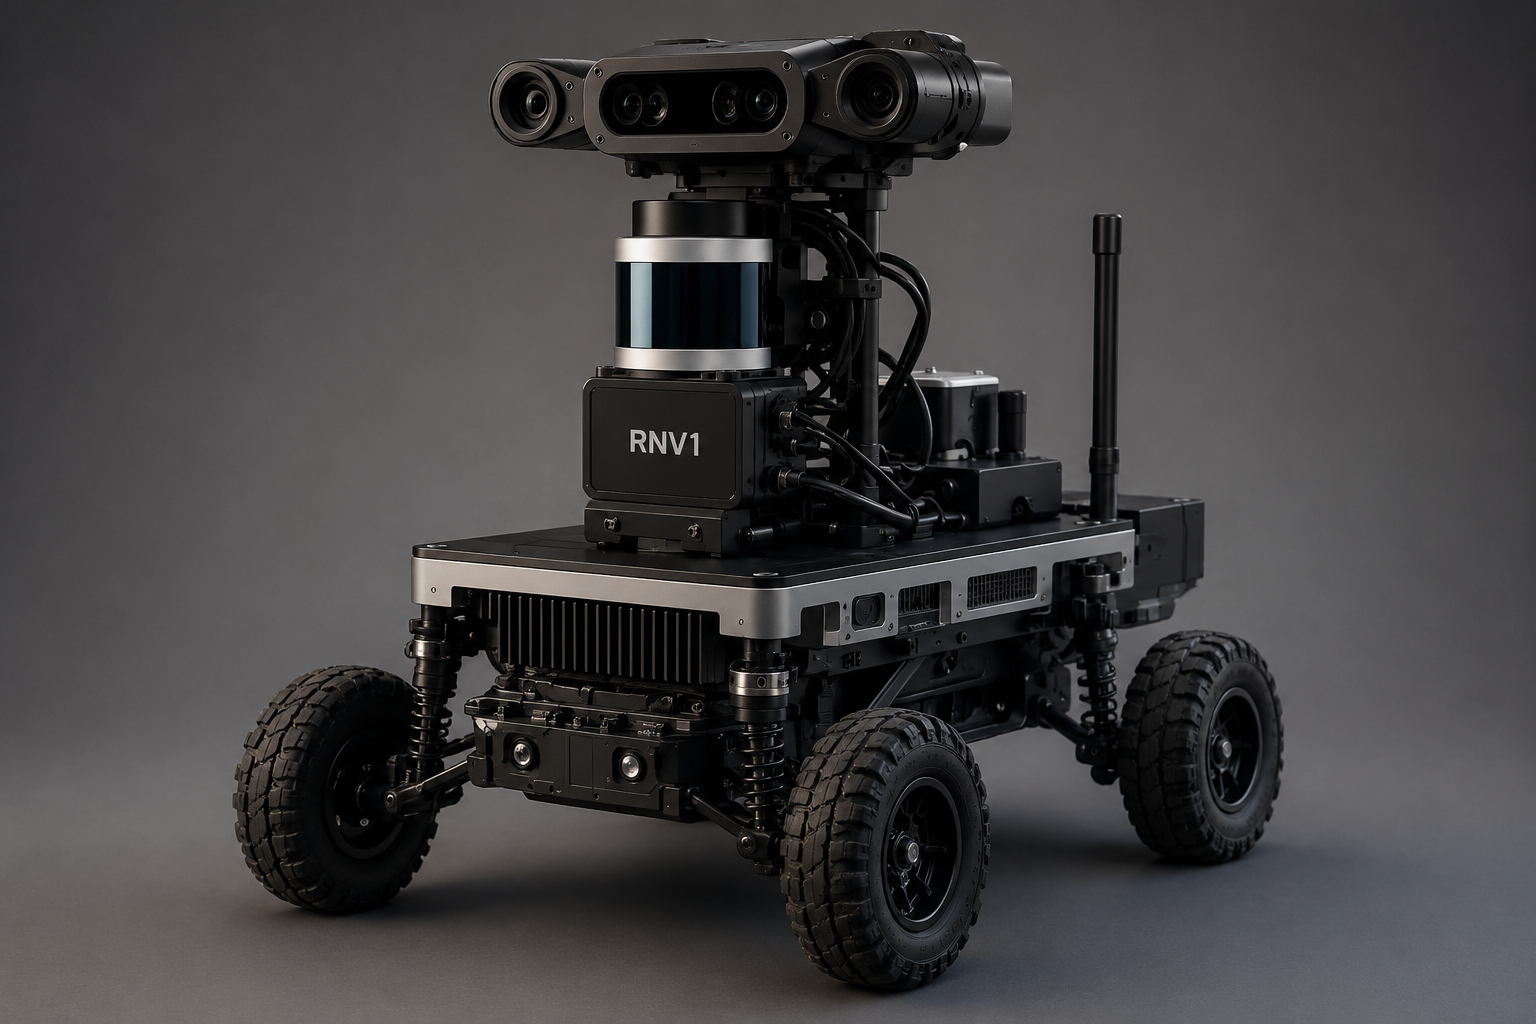
A field-oriented mobile robotics project for examining sensing, local intelligence, operator control, and recovery behavior as one visible system.
Purpose
Explore how a physical platform can sense conditions, surface uncertainty, and keep an operator in the decision loop.
Current boundary
The published image is a platform concept. It is not represented as a field-test photograph or a performance claim.
Evidence today
Current public record: active project framing and platform concept.
Next public milestone
Document a public-safe first systems note when a test record is ready.
Owner
Robotics
Keep the record honest